Run the whole HMI with nothing plugged in
PreciSim is an HMI for precision motion and 2D vision machines with a virtual device engine built in. Install it, open the camera view, jog three axes and run all seven calibration chains, each one checked against the ground truth inside the engine.
Windows 10/11 · no hardware required · free edition never expires
This is what opens
Screenshots of the software running.
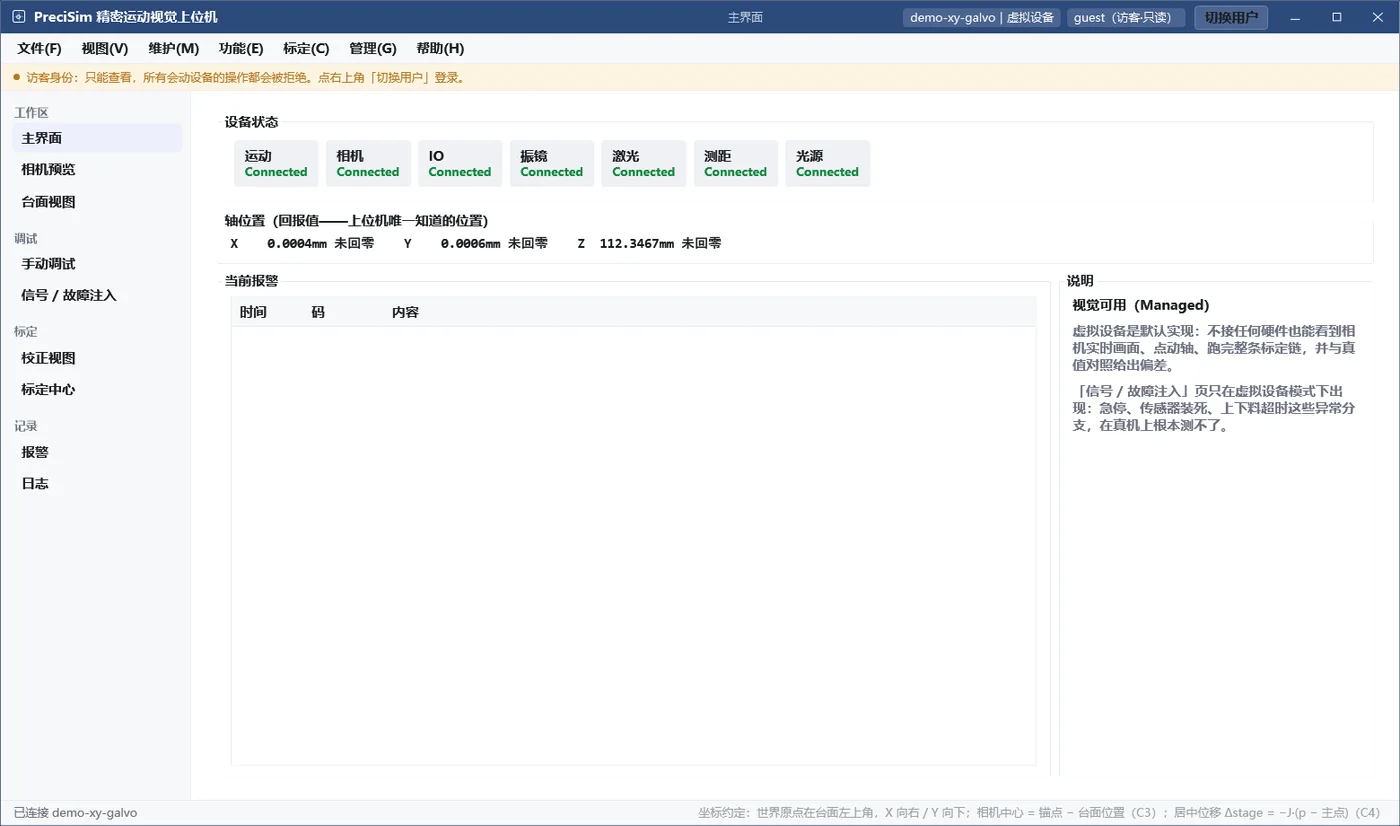
An HMI in industrial form
Four roles: guest, operator, engineer, administrator. The main page shows the connection state of seven device types and the axis positions. Alarms have a popup and a history; logs, manual jog, and signal and fault injection each get their own page.
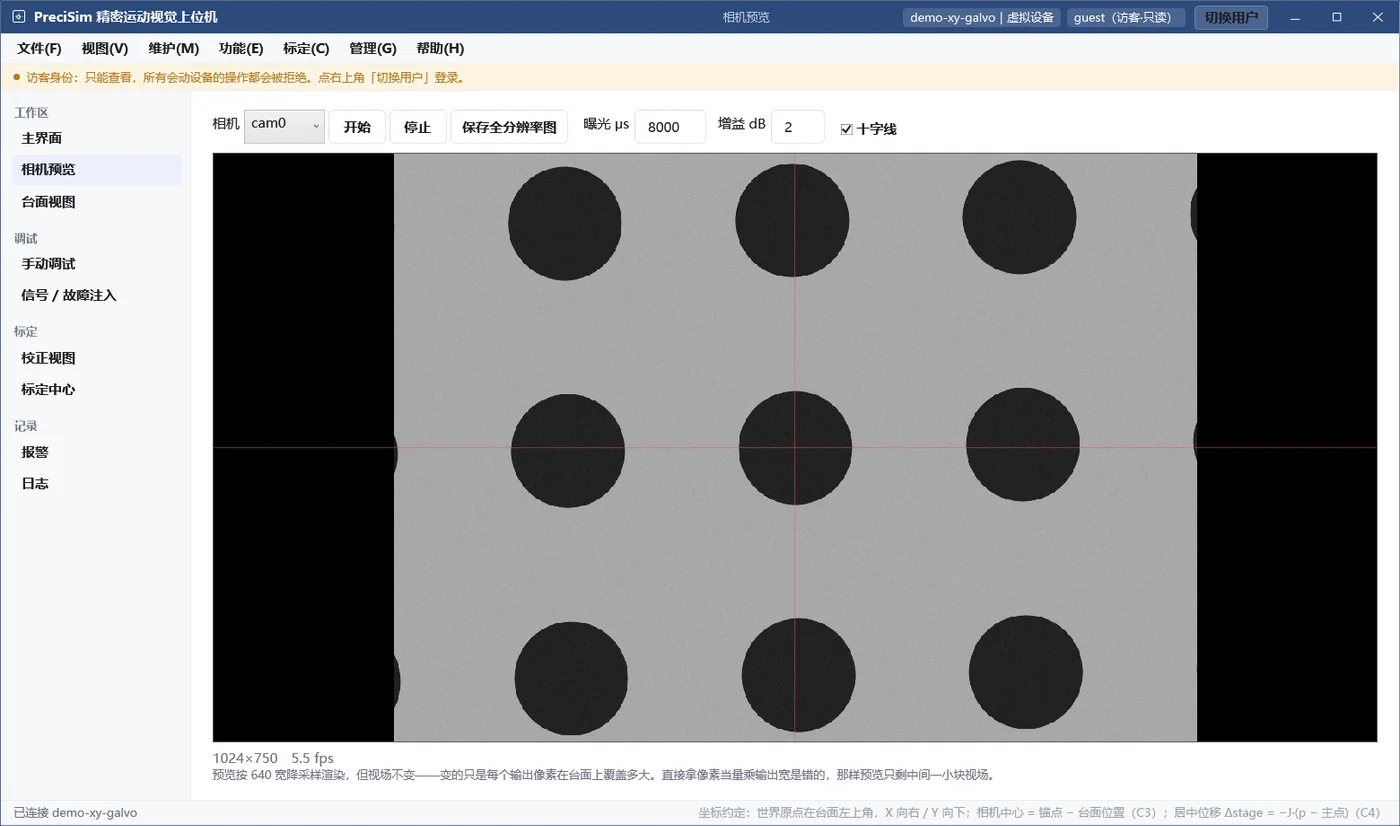
A machine with nothing wired up
Camera, three axes, galvo, laser, rangefinder, lighting and 22 IO points, all virtual. Camera frames are rendered per exposure, gain, depth of field and noise; axes carry pitch error and repeatability, so the reported position is never the true one.
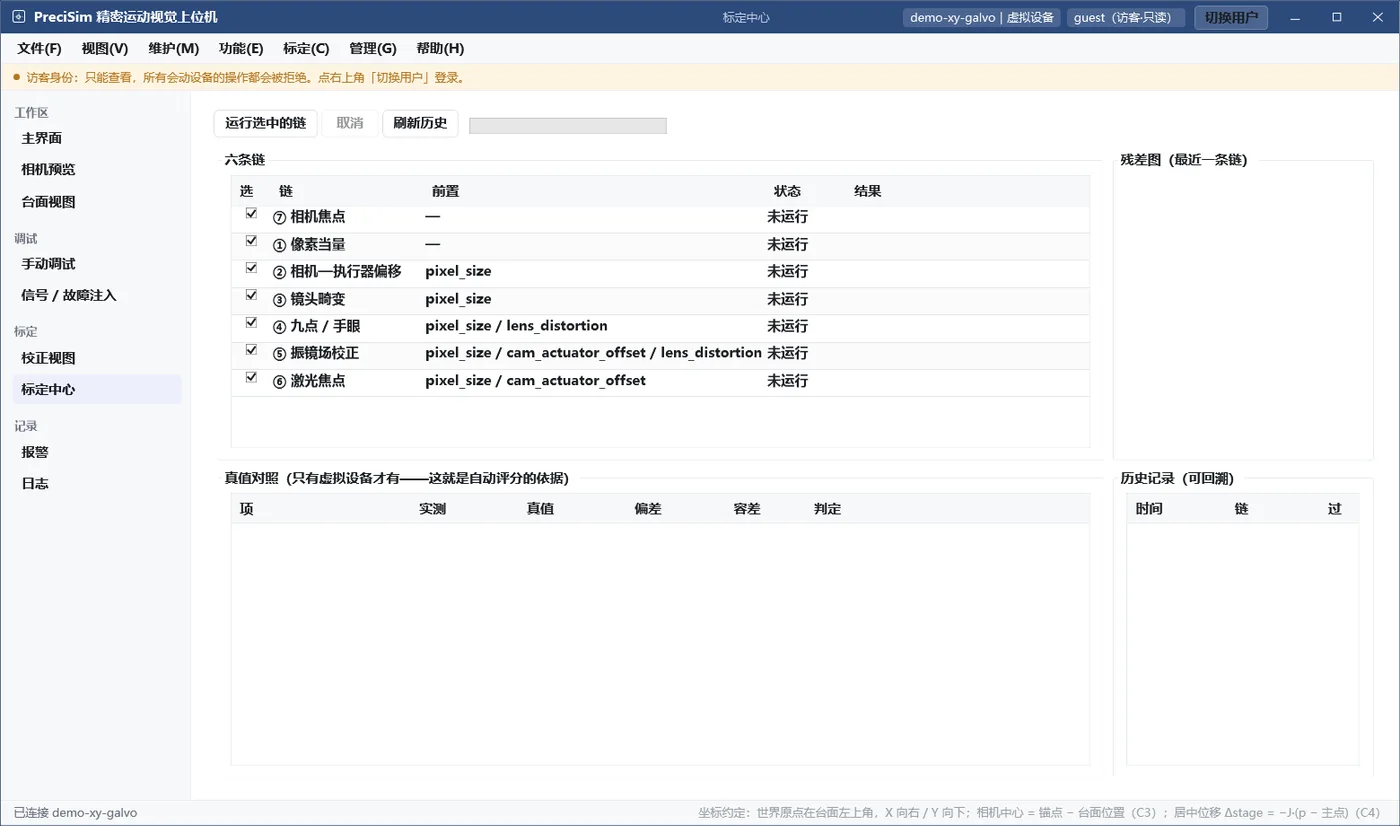
Seven calibration chains scored against truth
The calibration centre runs all seven chains in dependency order. Each chain ends with measured value, true value, deviation, tolerance and verdict, with the residual plot and the history kept for review.
Camera frames are computed from physics
Defocus turns depth of field into a blur radius, exposure scales the signal while the noise stays put, and the same seed reproduces the frame byte for byte. Both series below were captured from the engine by a script, with the full frame on the left and the central 320 pixels enlarged on the right. Use the slider to switch steps.
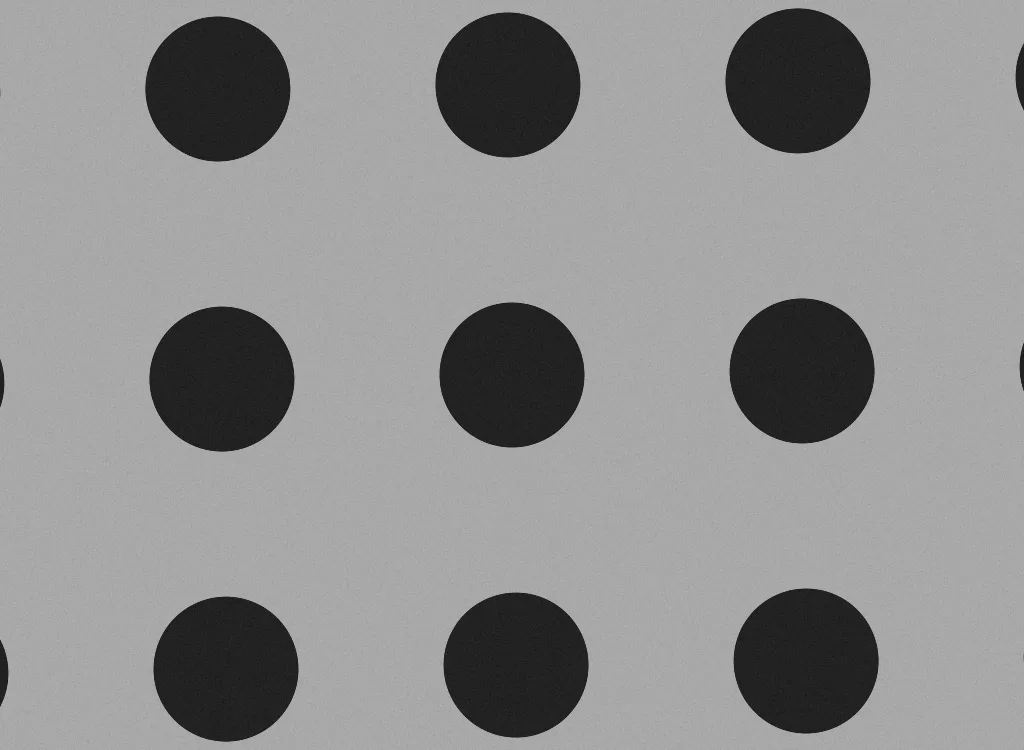
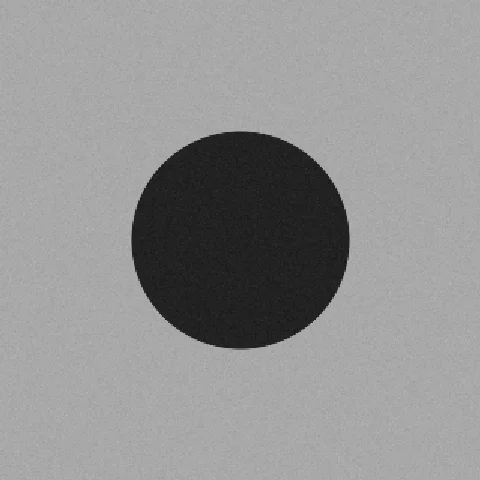
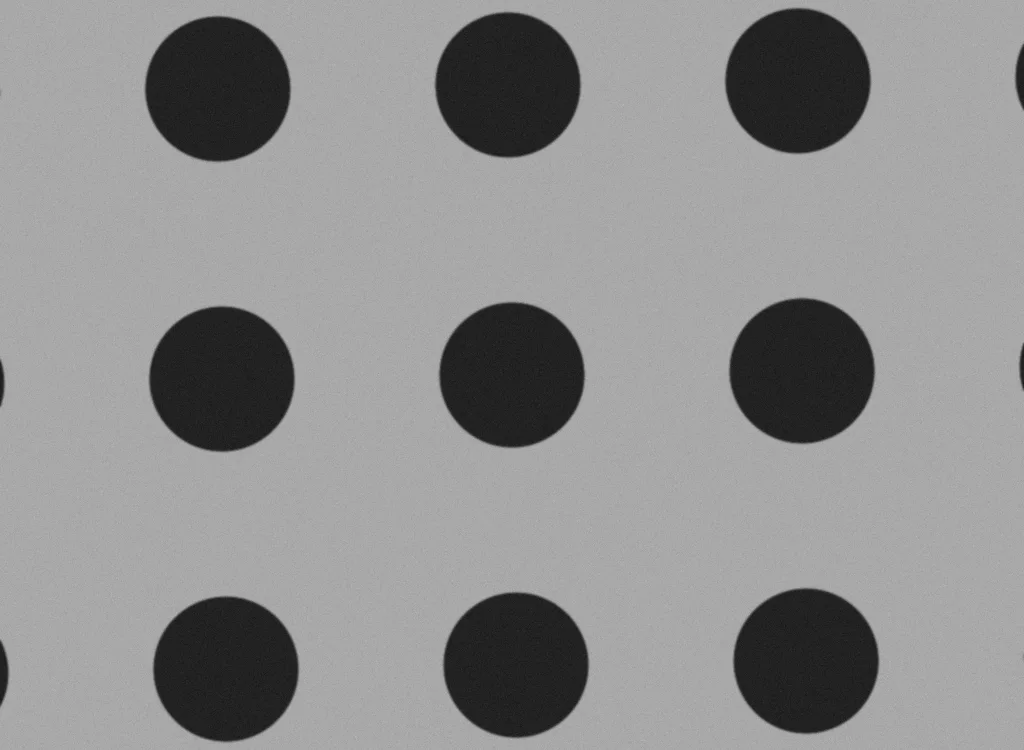
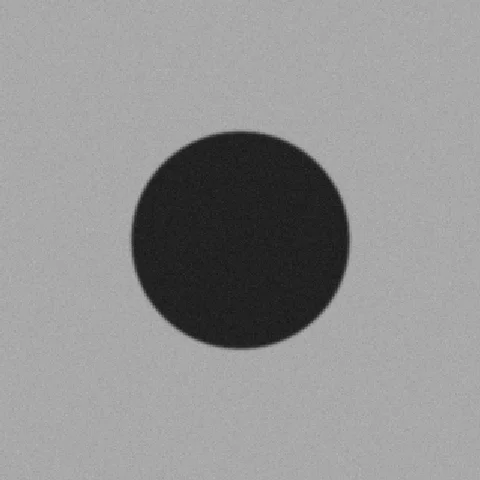
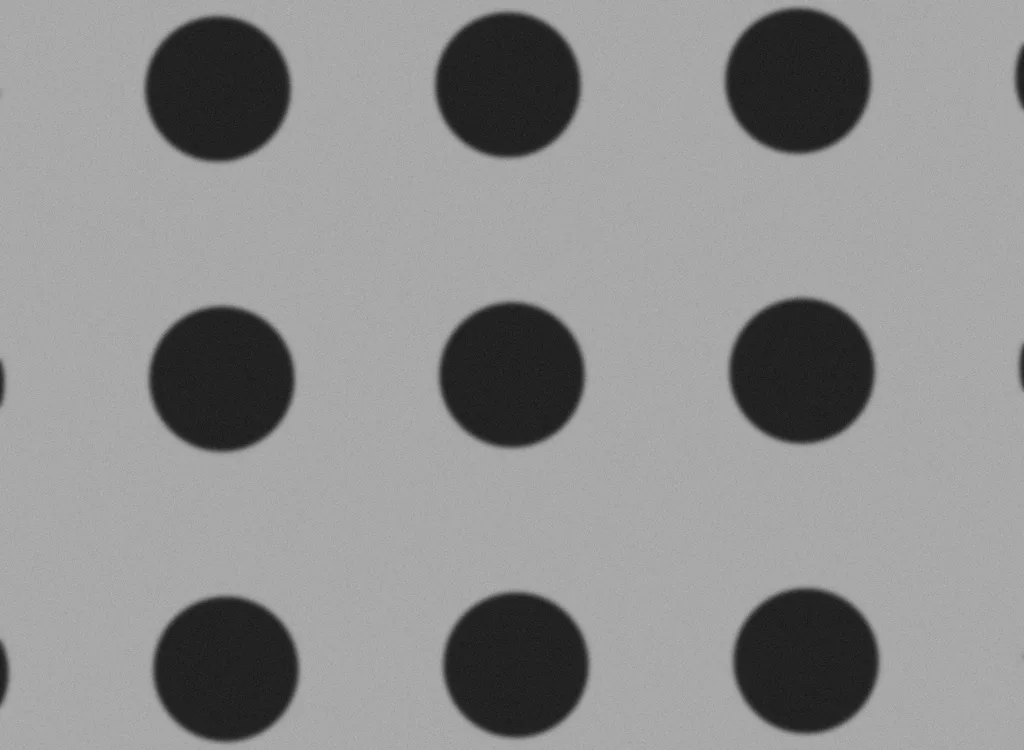
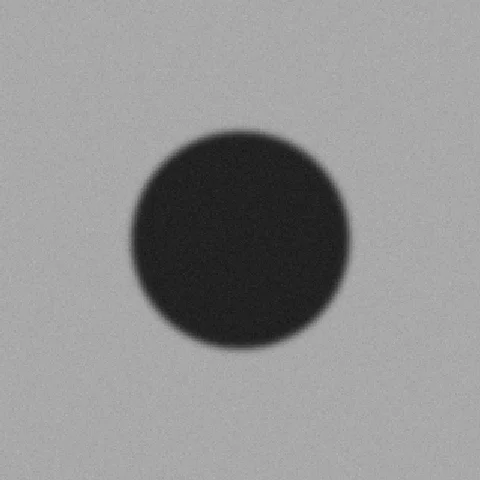
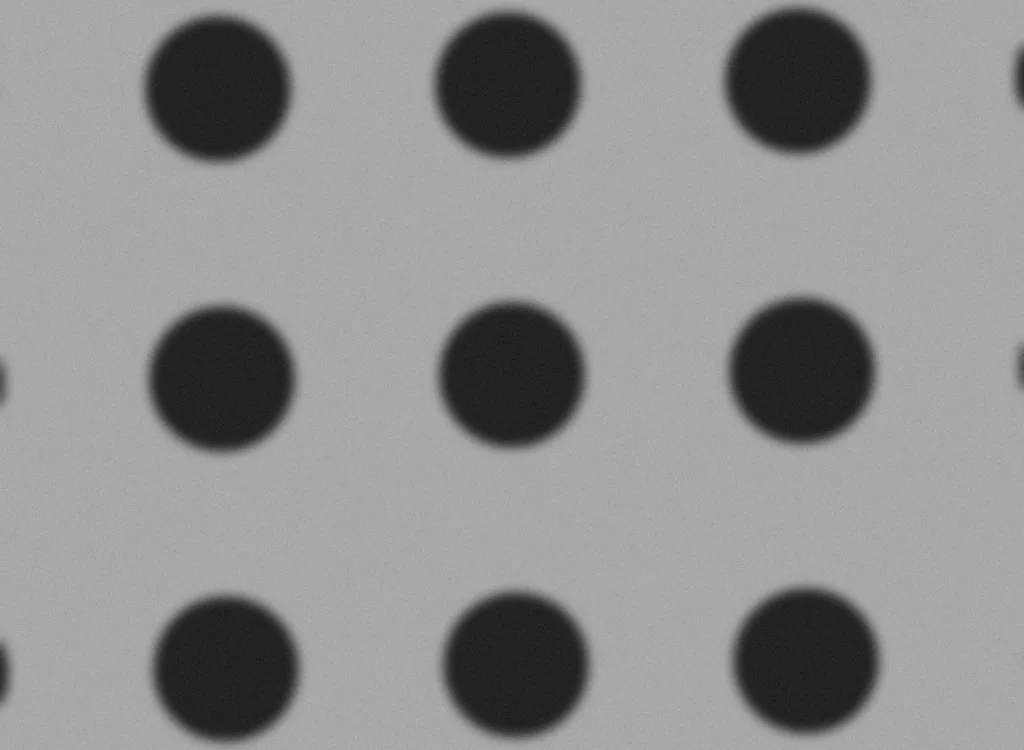
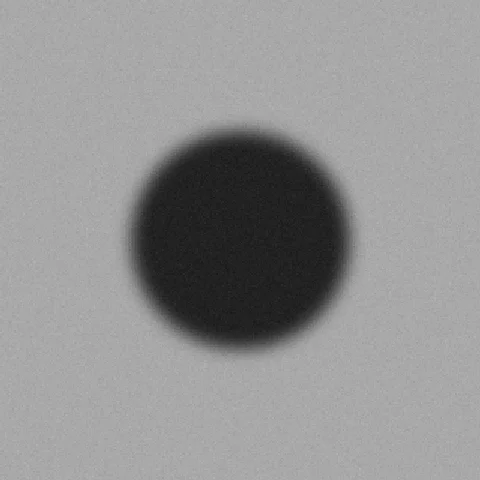
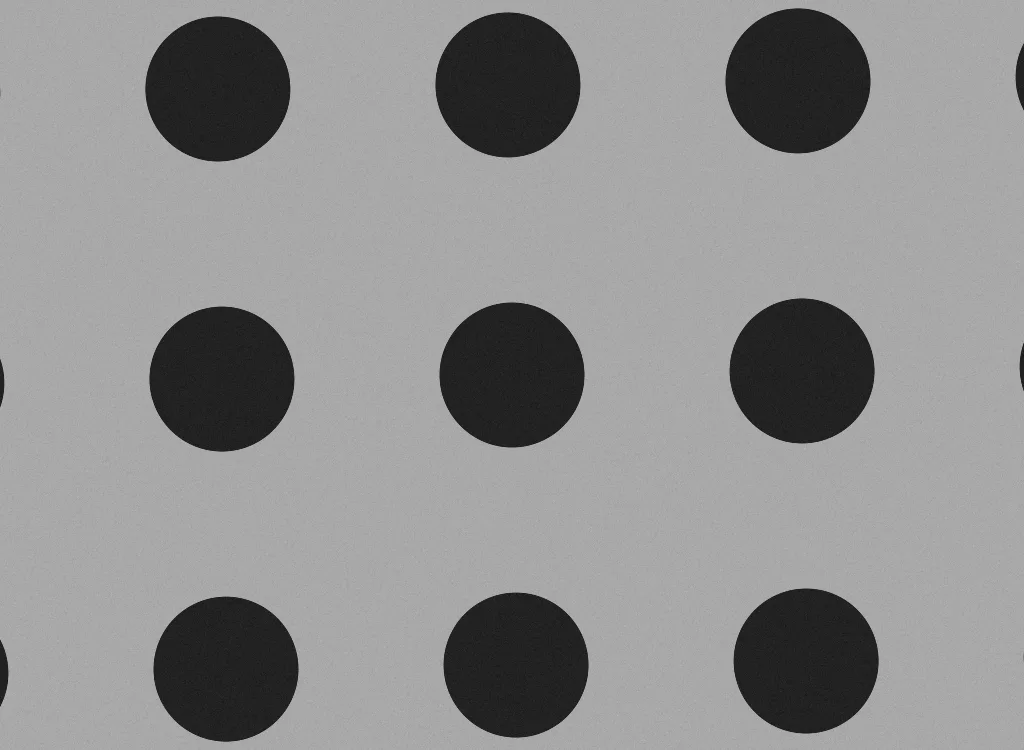
Frames come straight from the engine, the same image stream the camera page in the app receives.
Seven calibration chains, each ending with a deviation
The calibration centre runs them in dependency order, and any one can be re-run on its own.
① Pixel size
pixel_sizeµm/px in X and Y, axis rotation, non-orthogonality, residual RMS.
② Camera to actuator offset
cam_actuator_offset(Δx, Δy) from the camera centre to the laser or probe landing point.
③ Lens distortion
lens_distortionk₁ / k₂ from a dense circle grid, reprojection residual RMS.
④ Nine-point / hand-eye
hand_eyeAffine transform and residual between commanded and vision-measured positions.
⑤ Galvo field correction
field_correctionThe galvo marks a grid across the field (11×11 by default), each point is measured; reports max error before, residual after, field coverage.
⑥ Laser focus
laser_focusSweep Z for the smallest spot diameter.
⑦ Camera focus
camera_focusSweep Z for the sharpness peak; tolerance one notch looser than laser focus.
All seven chains implement one interface: each declares its steps and prerequisites and returns a result, so the wizard, progress, cancel and archive are shared. In the algorithms source, PixelSizeProcedure.cs is the template.
Source guide →The engine is closed. The model is not.
Why trust numbers from a virtual device? The six imaging steps, axis errors, defocus, noise, and the definitions of truth and tolerance are all written out in the docs. Open formulas, closed implementation: anyone who can follow the maths can check it. On the right are the error sources injected into the sample machine; turn them up, rerun, and watch how they reach the calibration results.
Read "Physics and models"| X pitch error | 0.8µm | 50 mm period |
| Y pitch error | 0.6µm | 40 mm period |
| Repeatability | 0.2µm | X / Y |
| Axis readout noise | 0.5µm | Gaussian σ |
| Image noise | 3.0 | grey levels, Gaussian σ |
| Range finder noise | 0.8µm | |
| Camera depth of field | 0.17mm | sets the defocus blur radius |
What it solves
The virtual machine is always available. A bad calibration crashes nothing, and error parameters can be turned up until the consequence is visible.
The virtual device knows the truth, so every chain ends with a deviation and a verdict.
Device interfaces, the Station/DAG workflow and the calibration chains are the shared layer. A new machine changes configuration and device implementations.
Get the logic right against virtual devices first. On site, only the difference between real hardware and virtual remains.
Source is a one-time purchase, updates have no end date
After payment your Git account is added to the private repository as a read-only member, and every later version is a git pull away. Updates have no end date.
See source pricing- The repository invite is sent automatically after payment
- The repository builds from a clean clone, with nothing from our environment
- A source guide tells you which file to read first
Five labs
Each lab has a goal, steps, pass criteria, common mistakes and review questions, ready for classroom use.
Lab 1 · Pixel size calibration
Calibrate mm/px and verify against ground truth to within 0.05 mm.
Lab 2 · Hand-eye calibration
Solve the camera-to-motion relationship with the nine-point method, and see why the two configurations must not be mixed up.
Lab 3 · Motion error and backlash
Measure backlash, compensate it, and understand the difference between repeatability and accuracy.
Lab 4 · Z focus calibration
Find the best focal plane from a sharpness curve, and watch noise push it around.
Lab 5 · Galvo field correction
Map and correct in-field distortion, bringing the residual under 15 µm RMS.
Frequently asked
What does the free edition do, and does it expire?
The free edition includes the complete virtual machine, every machine model, all seven calibration chains and every lab. It never expires and needs no account. Physics, precision and ground truth are identical to the professional edition; the difference is the external interfaces and the commercial licence. The free edition is for personal learning and evaluation; for use at work, buy the professional edition.
The engine is closed source. How do I know the numbers are right?
The docs contain a full "Physics and models" chapter: world and imaging, axes and errors, optics and defocus, noise, ground truth and tolerances. Open formulas, closed implementation. Check the arithmetic yourself.
If I buy the source, do future updates cost extra?
No. Pay once, and every future version is a git pull away.
Our lab network has no internet. Can we still use it?
Yes. Offline activation turns a machine code into an activation code with no network involved, and a failed online check carries a 30-day grace period, so an outage on our side does not stop a class.
What if I change computers?
Paid licences count machines: three for the professional edition or a single source package, five for both source packages. When you switch computers, deactivate the old one yourself from your account. The free edition needs no activation.
Does it work with real hardware?
The device layer is an abstraction: virtual and real devices implement the same interfaces. Once the logic works against virtual devices, going to real hardware means swapping device implementations and configuration. The real-device implementations are placeholders today, so you write that layer for your own hardware.
Finish the first lab
Thirty minutes, no hardware, and a real deviation number at the end.